Technical specifications
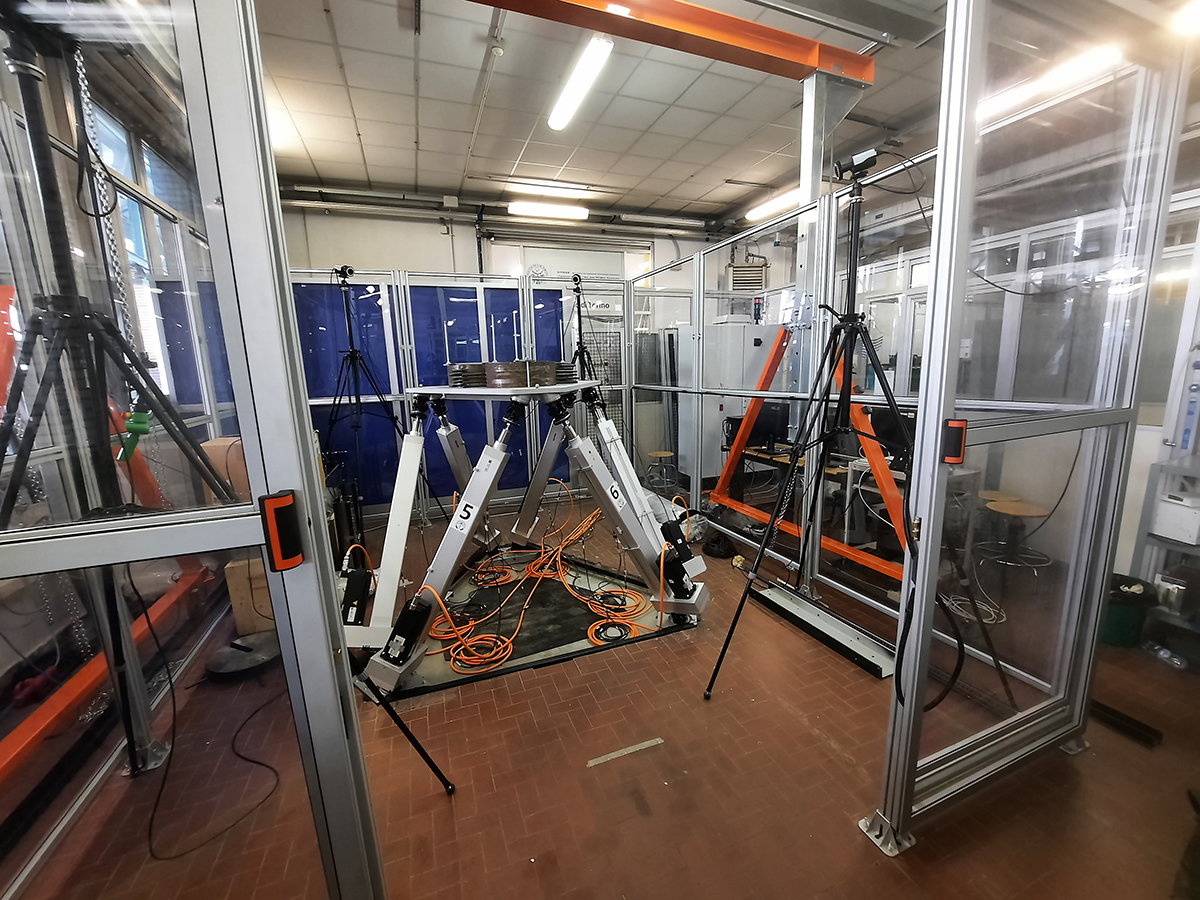
6-DOF HEXAPOD
This hexapod represents a Gough-Stewart platform and has been conceived to provide 6 degrees-of-freedom positioning for a payload placed on board of the upper platform; feasible applications can be of different kind.
By means of software interface, the operator can create both periodical motion and random point-to-point time history, the controller of the hexapod executes inverse kinematics calculation, a real time oscilloscope can show command setpoint, calculated actual values for position, speed and acceleration and any other data acquired by sensors applied to the specimen.
EtherCAT ports are available to establish communication with any eventual Master controller of the User, so to make possible an Hardware-In-The-Loop simulation.
6-DOF Hexapod are available both with electro-mechanical actuators and with hydraulic servoactuators, depending on required performances and namely by the size of payload and by dynamics.
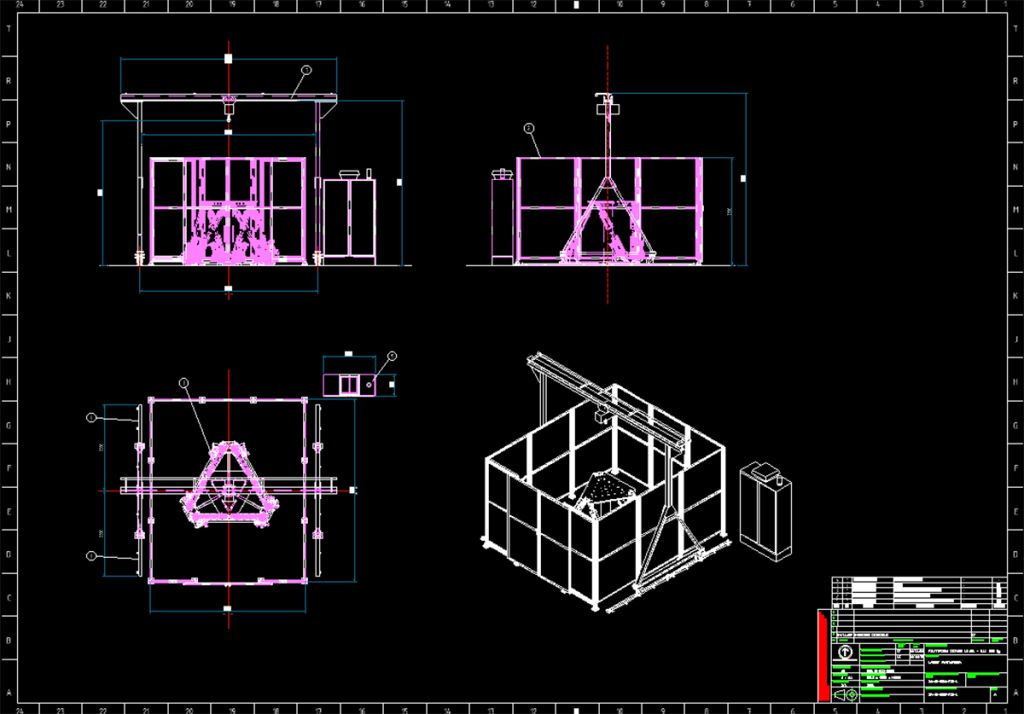
General assembly drawing
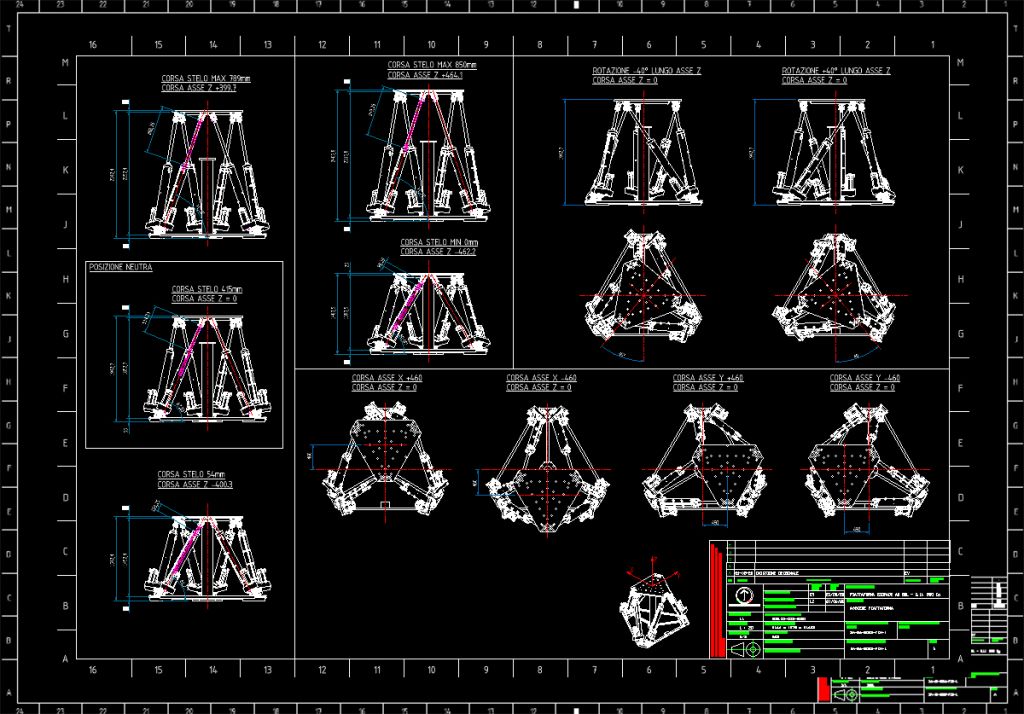
X-Y-Z translation
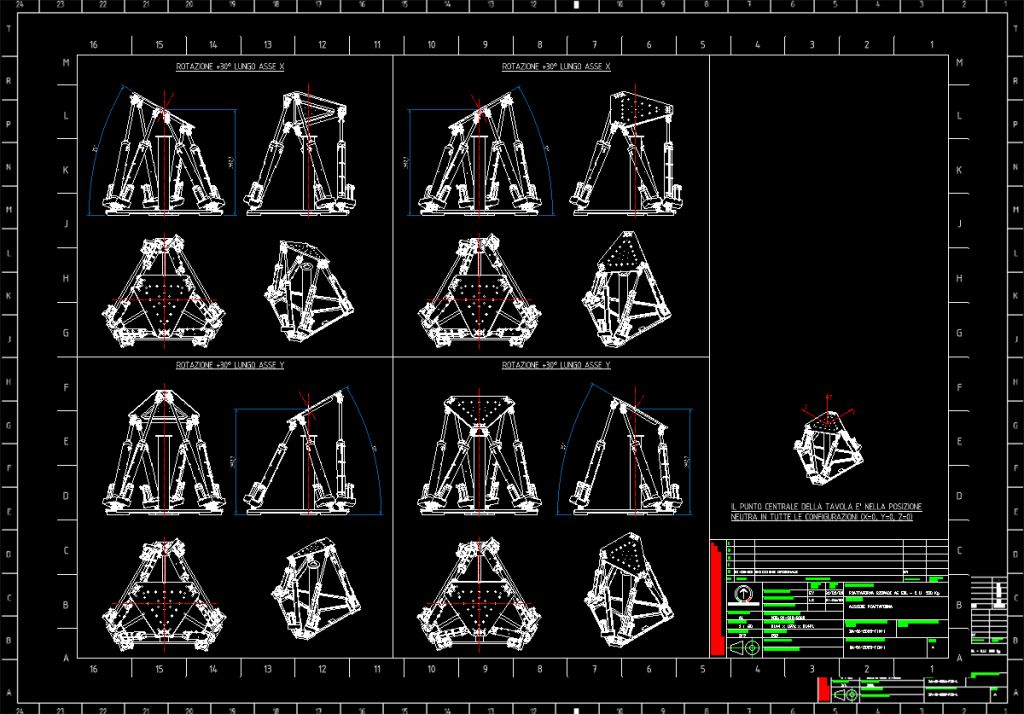
X-Y-Z rotation
| Performances (electro-mechanical platform) | Max value |
|---|---|
| Payload | 300 kg |
| X-axis translation | ± 460 mm |
| Y-axis translation | ± 460 mm |
| Z-axis translation (vertical) | ± 400 mm |
| Rotation about X-axis | ± 30° |
| Rotation about Y-axis | ± 30° |
| Rotation about Z-axis | ± 40° |
| Speed along the X-axis | ± 1,2 m/s |
| Speed along the Y-axis | ± 1,2 m/s |
| Speed along the Z-axis | ± 1 m/s |
| Rotational speed about X-axis | ± 100°/s (1,74 rad/s) |
| Rotational speed about Y-axis | ± 100°/s (1,74 rad/s) |
| Rotational speed about Z-axis | ± 140°/s (2,44 rad/s) |
| Acceleration along the X-axis | ± 8 m/s2 |
| Acceleration along the Y-axis | ± 8 m/s2 |
| Acceleration along the Z-axis | ± 8 m/s2 |
| Rotational acceleration about X-axis | ± 800°/s2 (13,95 rad/s2) |
| Rotational acceleration about Y-axis | ± 800°/s2 (13,95 rad/s2) |
| Rotational acceleration about Z-axis | ± 1100°/s2 (19,18 rad/s2) |